


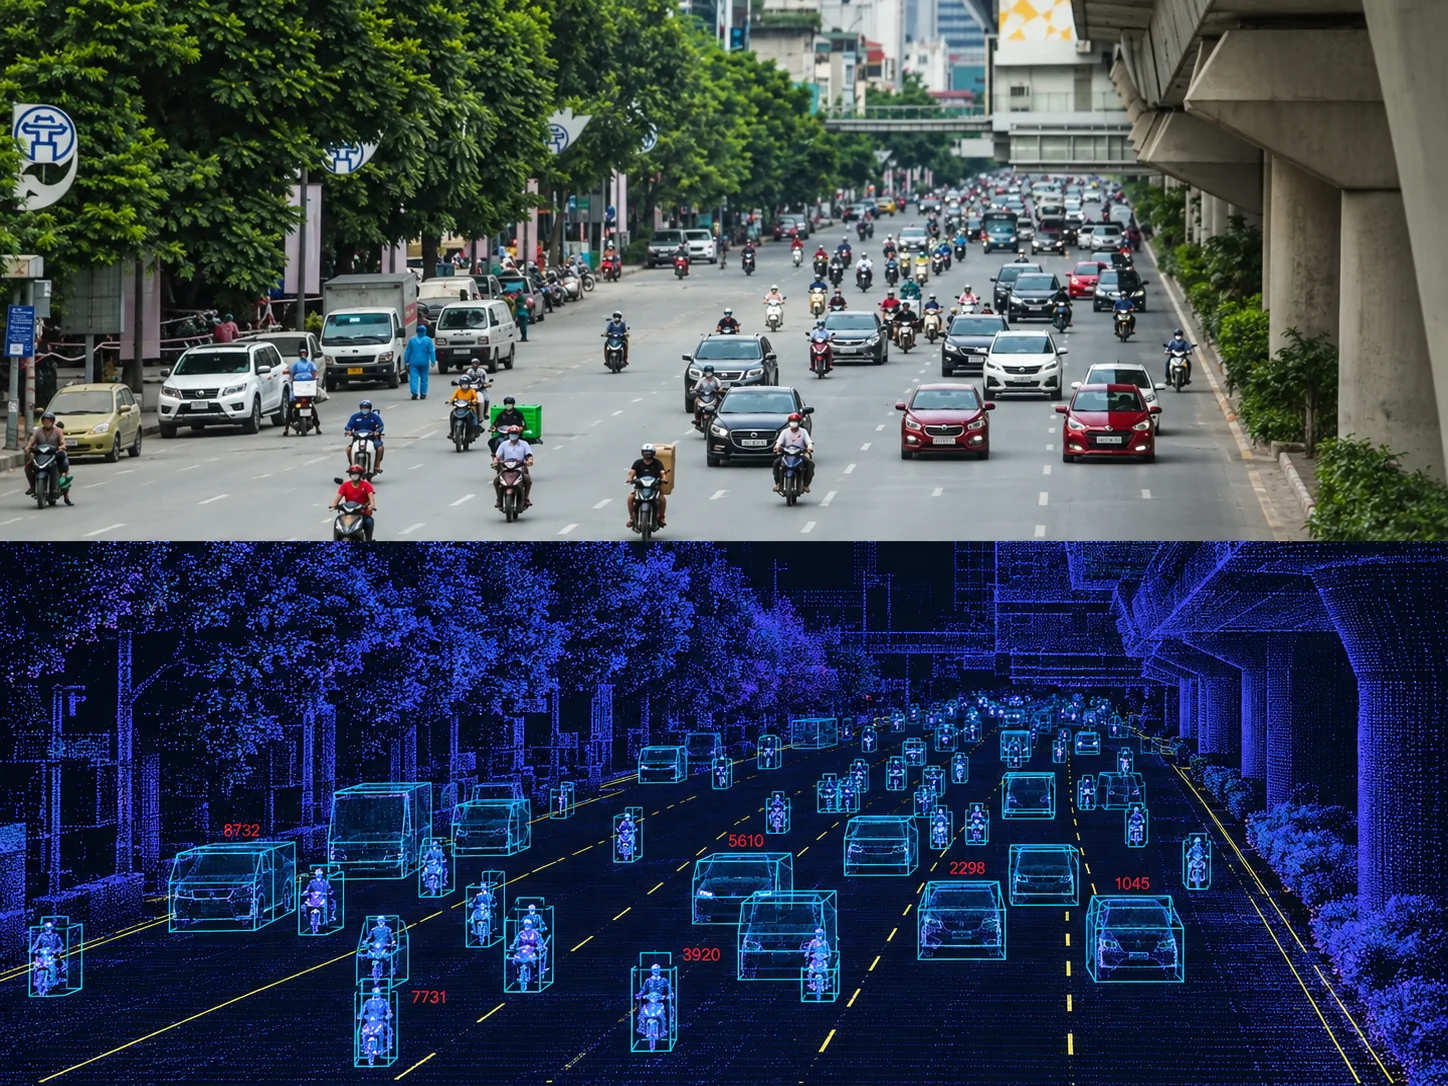
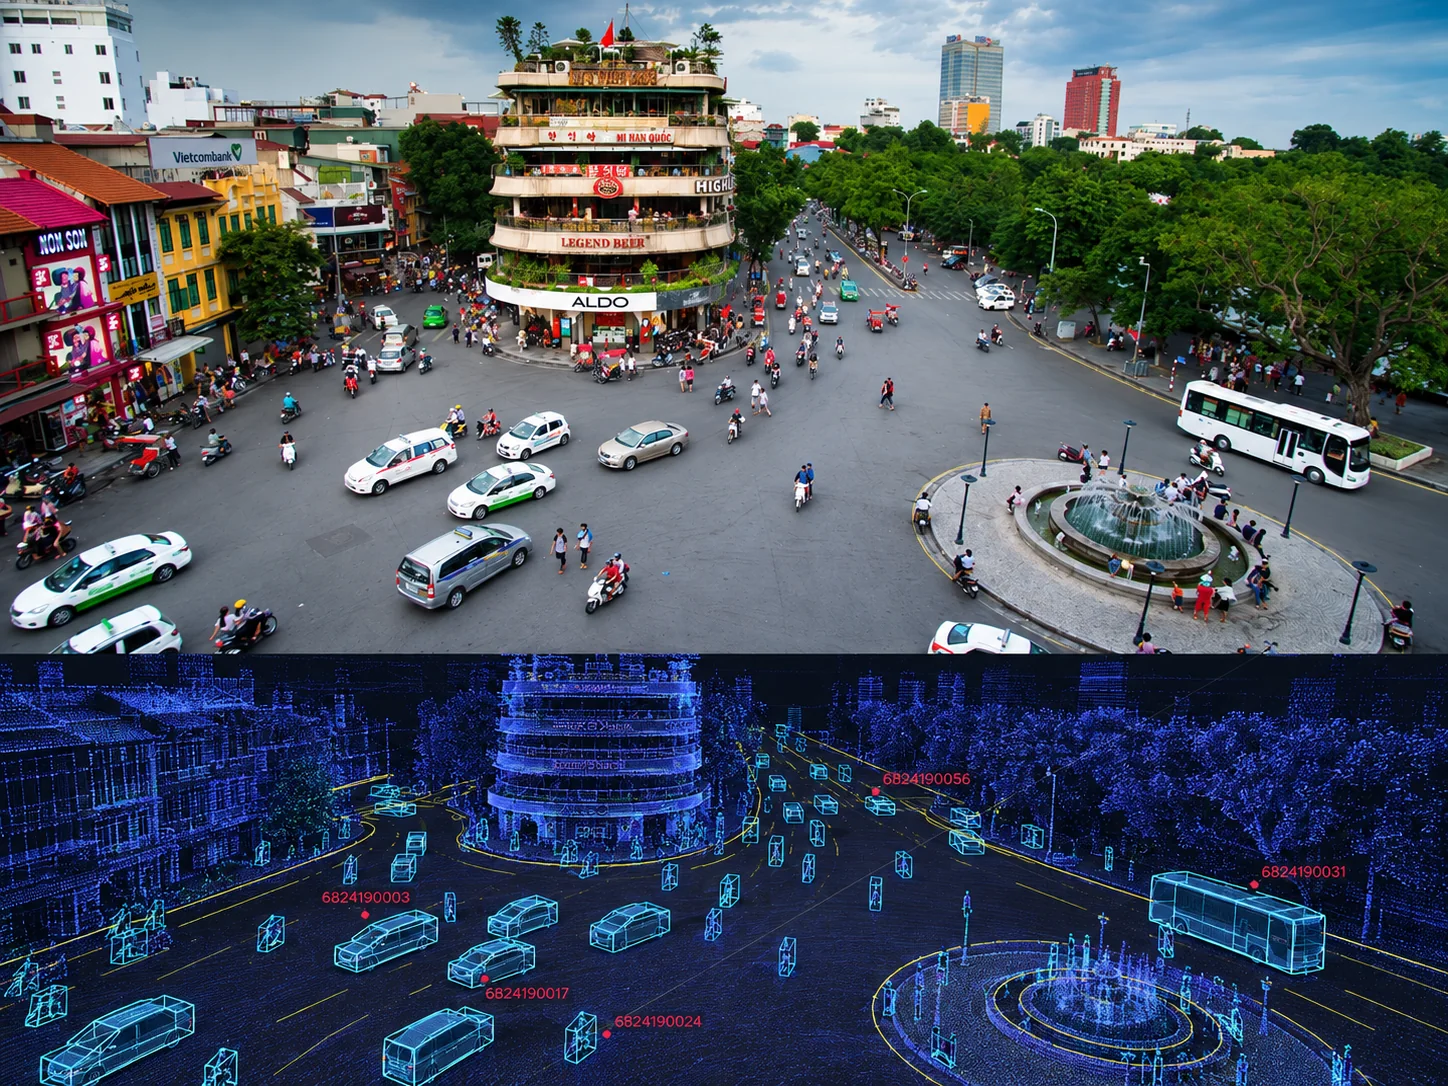
Sensor alignment
Synchronize camera, LiDAR and road context in time and space.
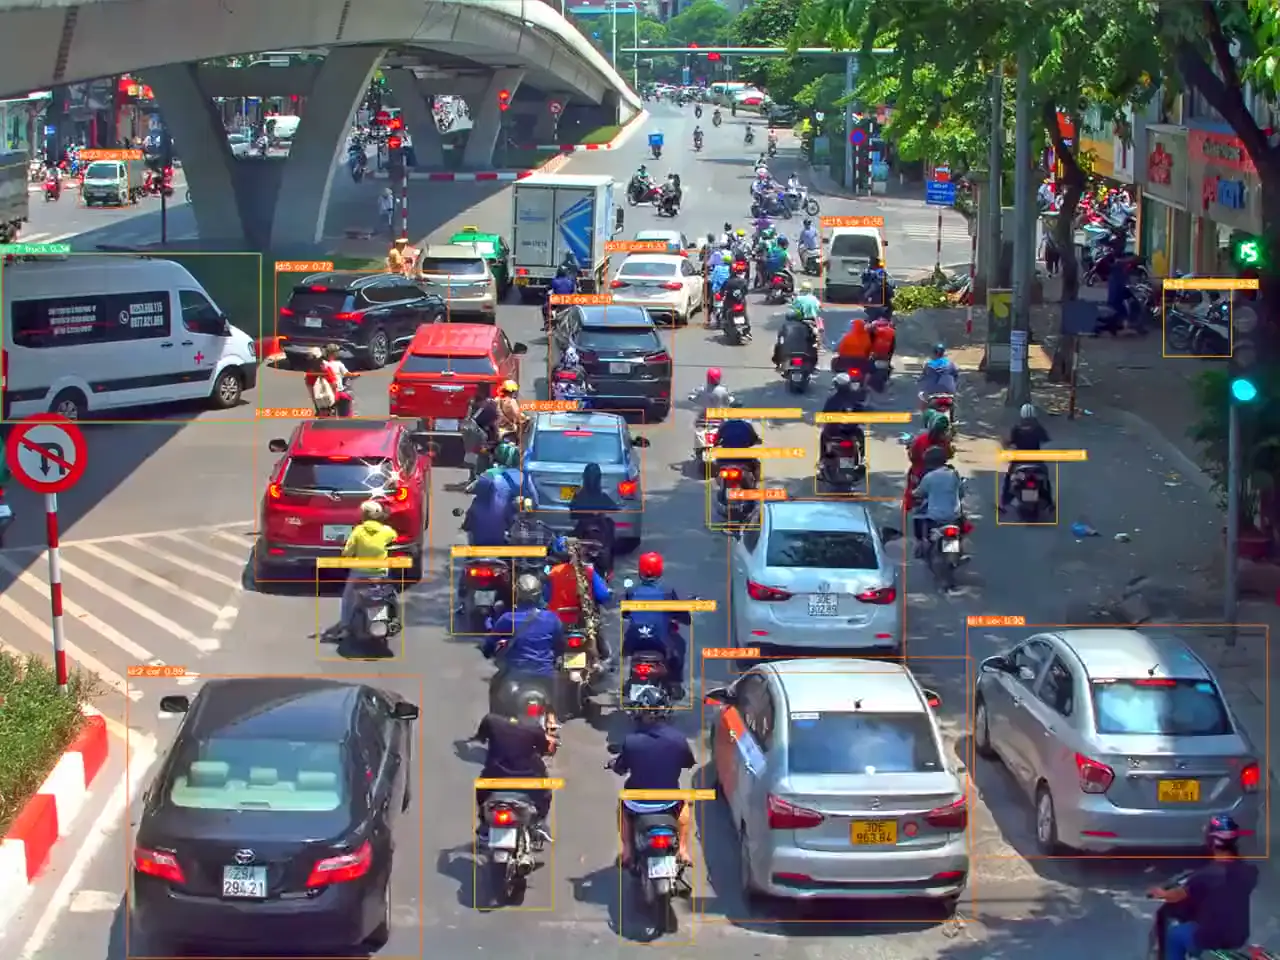
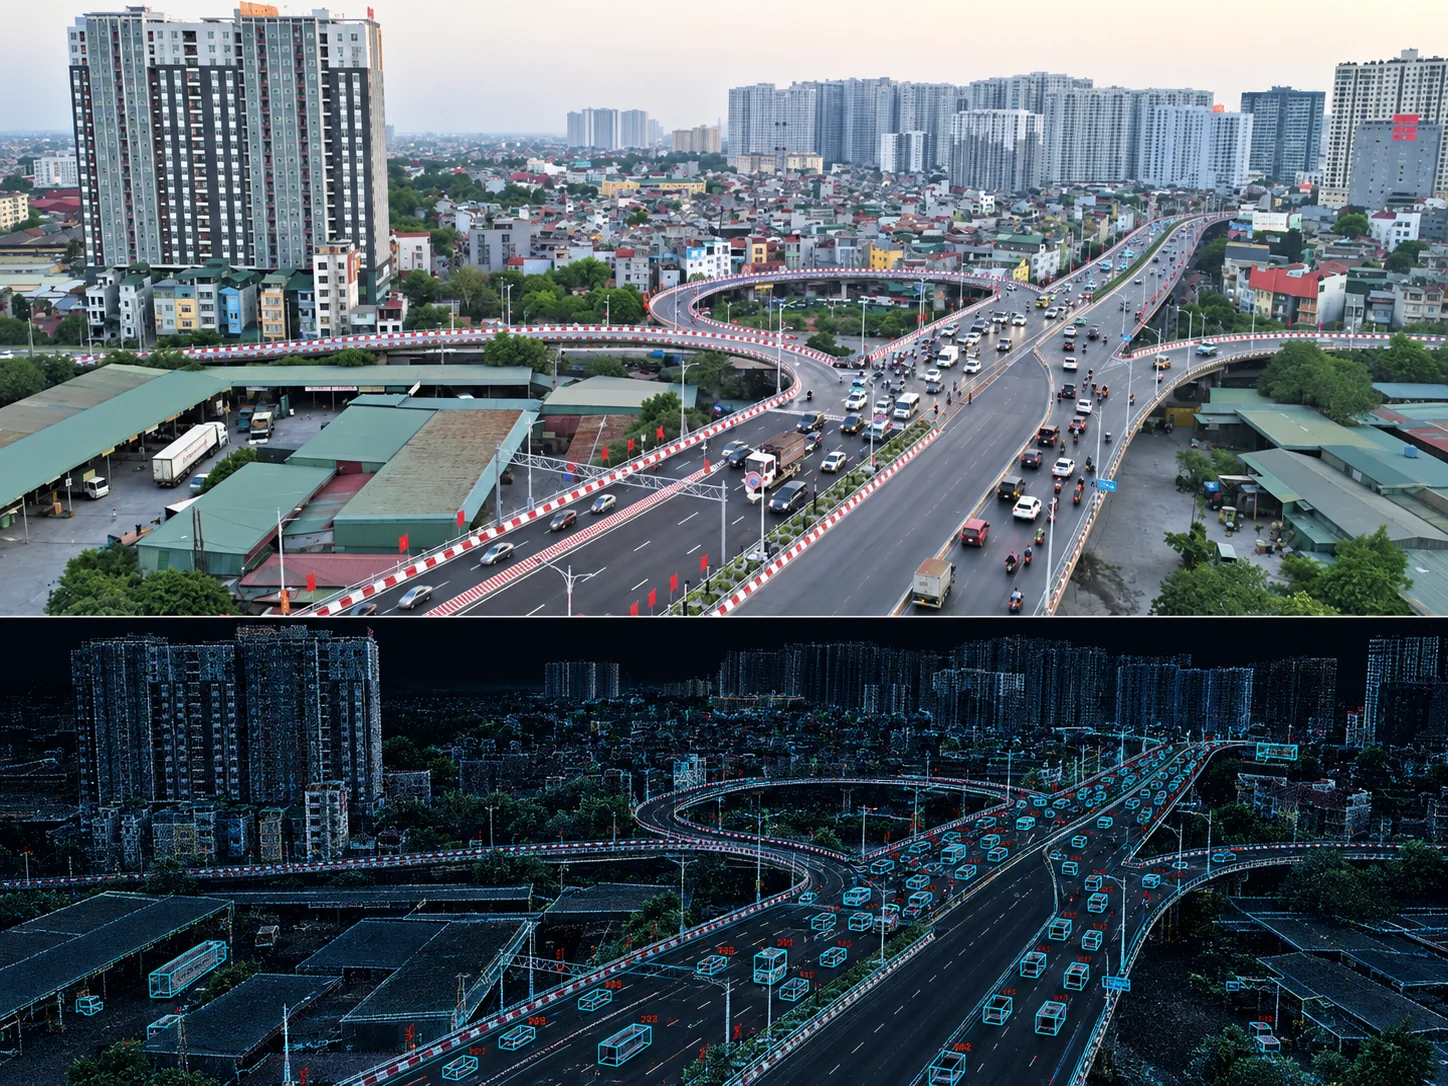
TeraFlow connects roadside sensors, 3D perception and tracking to show what is happening and how traffic is changing.
CAMERA + LIDAR
EDGE PROCESSING
3D TRACKING
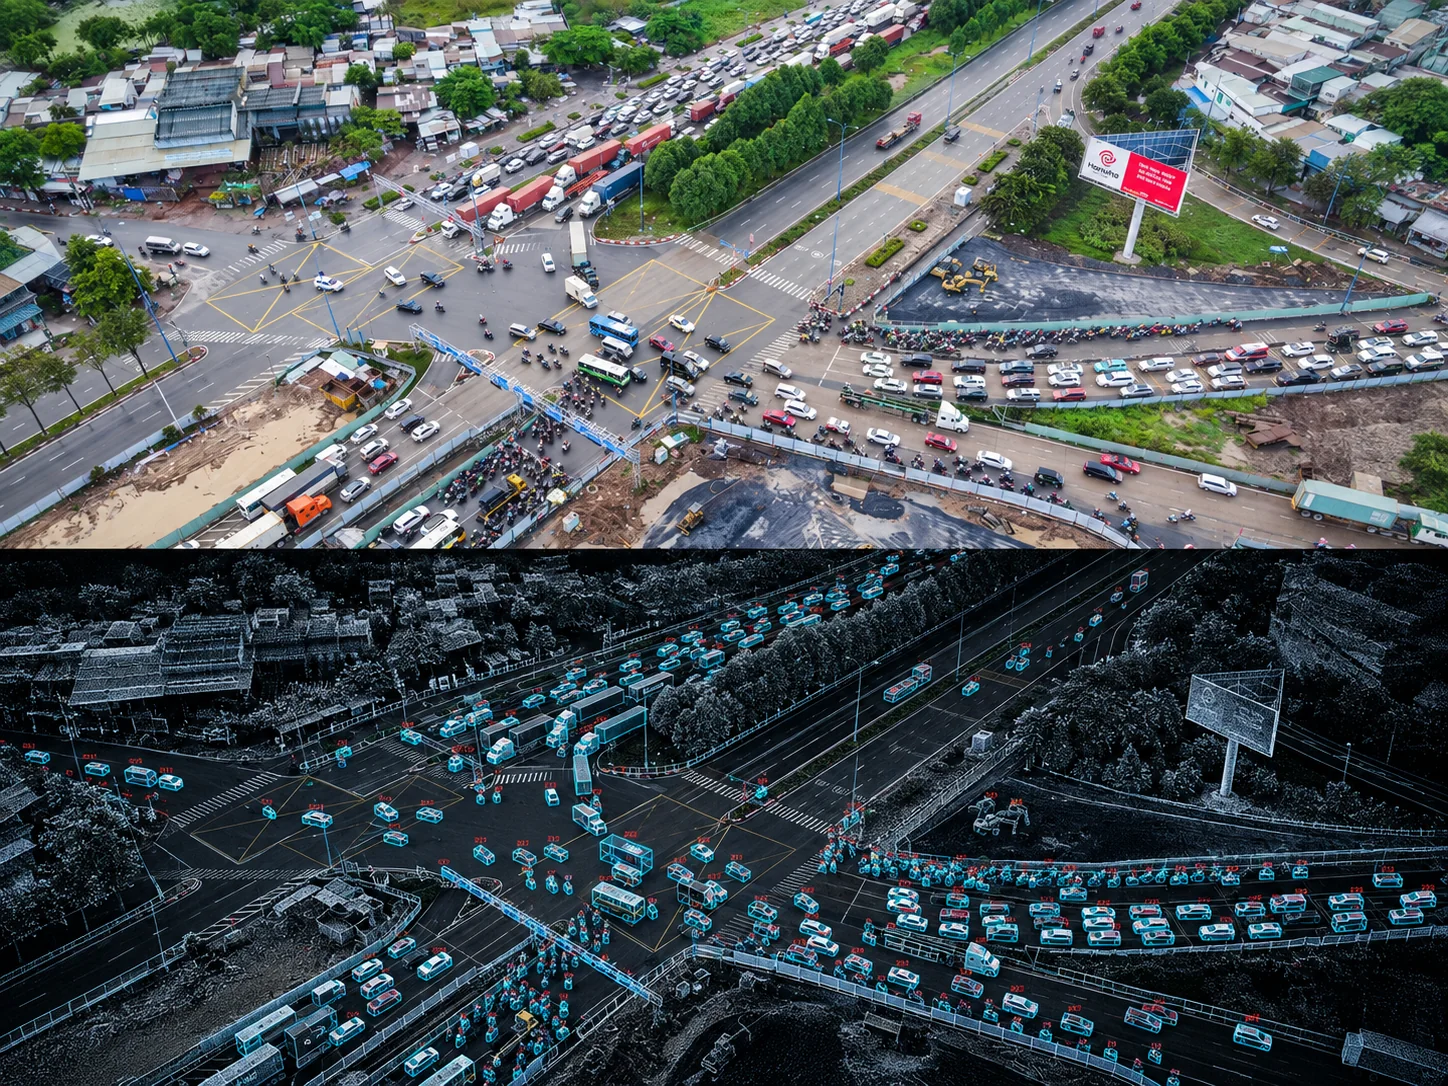


Camera provides appearance. LiDAR provides geometry and depth.
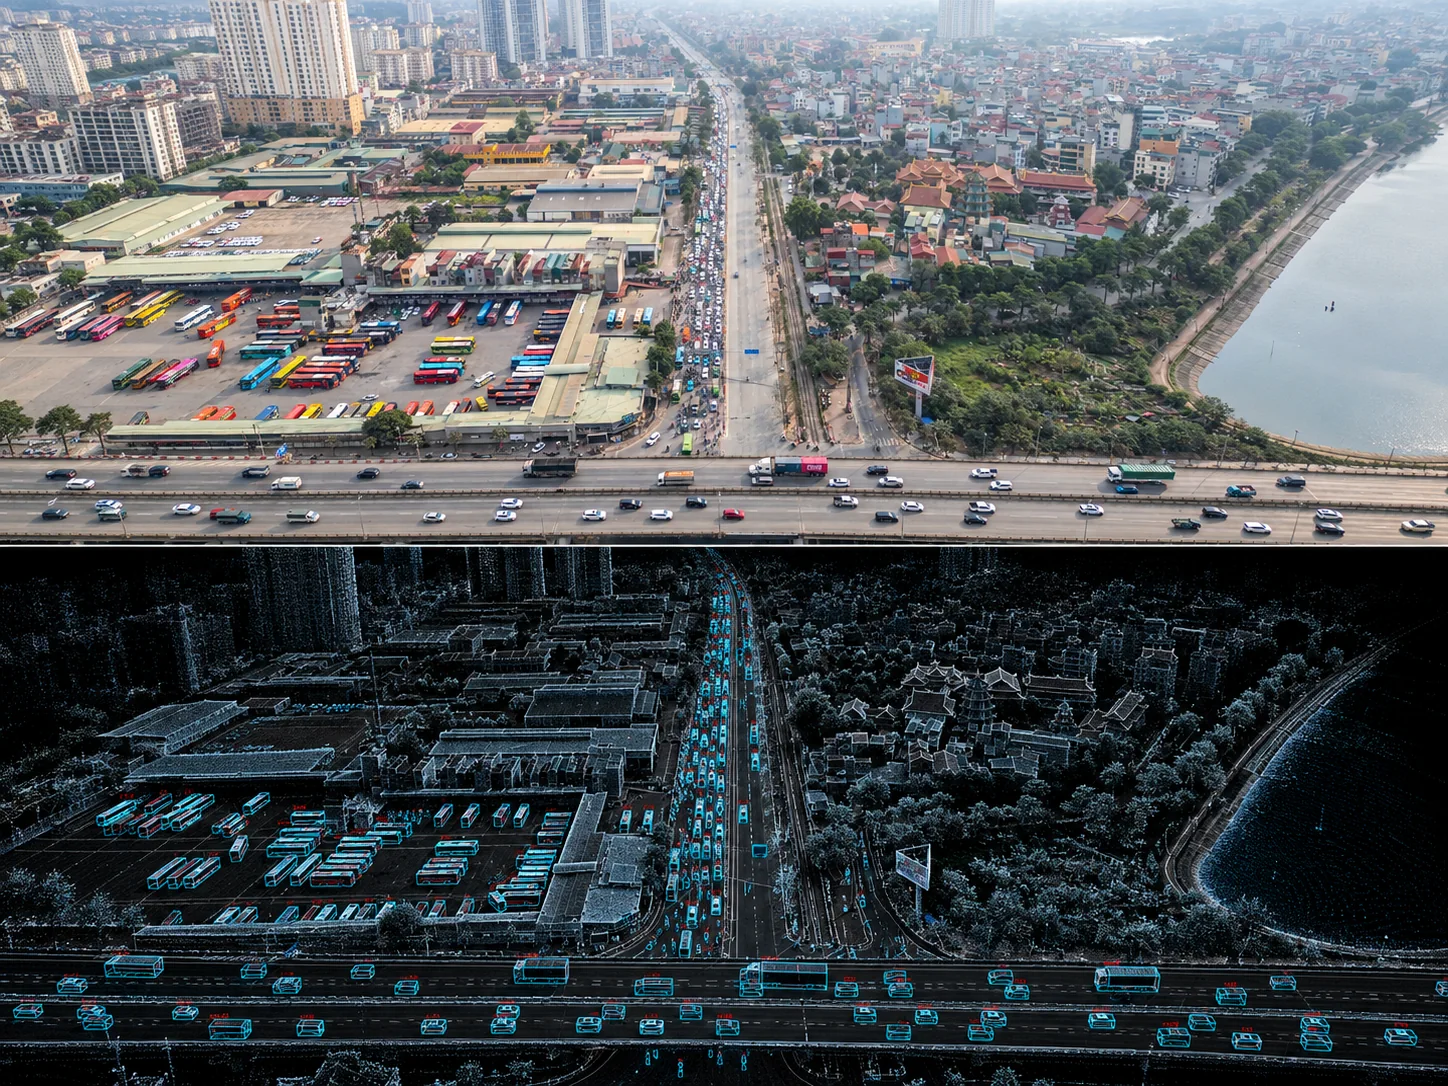
TeraFlow combines camera and LiDAR into a traffic view that can be measured, replayed and reviewed.
TeraFlow ResearchPerception → Twin → Decision Support
Continuous traffic-state awareness
Camera and LiDAR sensor fusion
Vehicles, pedestrians, cyclists and transit
Local perception and event filtering
Works with existing traffic systems
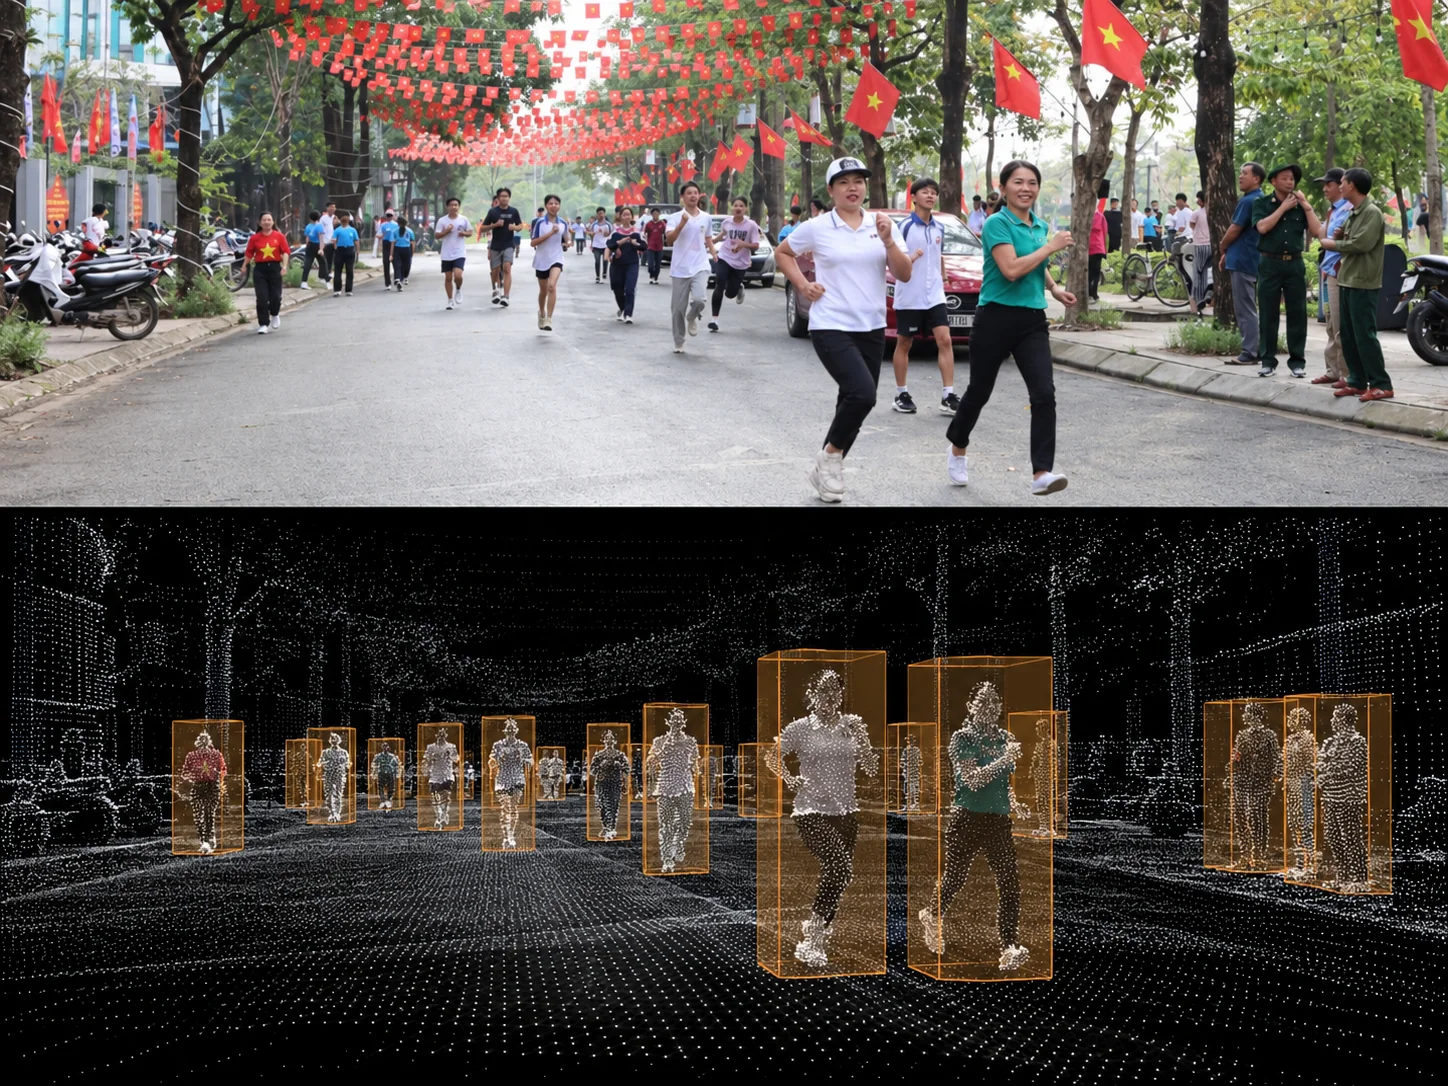
TeraFlow can process perception at the edge, limit retention and provide operational views that focus on movement rather than identity.
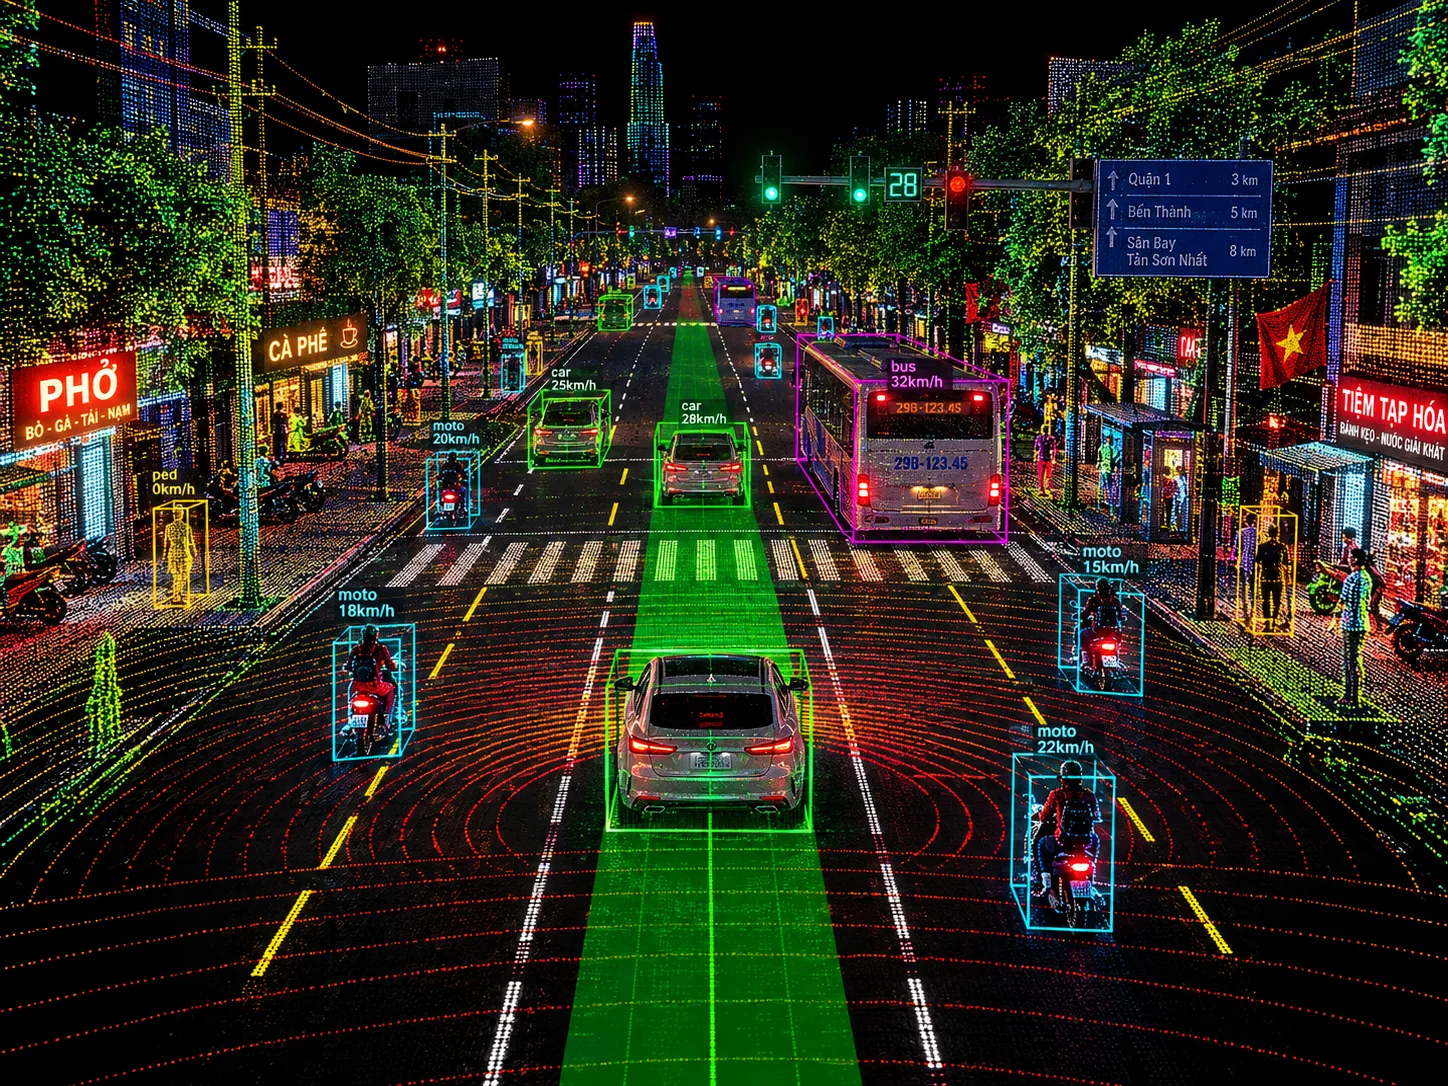
TeraFlow continuously rebuilds road activity into a spatial traffic model.
Vehicles, motorcycles, pedestrians, lanes, movement and events stay connected across camera footage, 3D perception and historical playback.
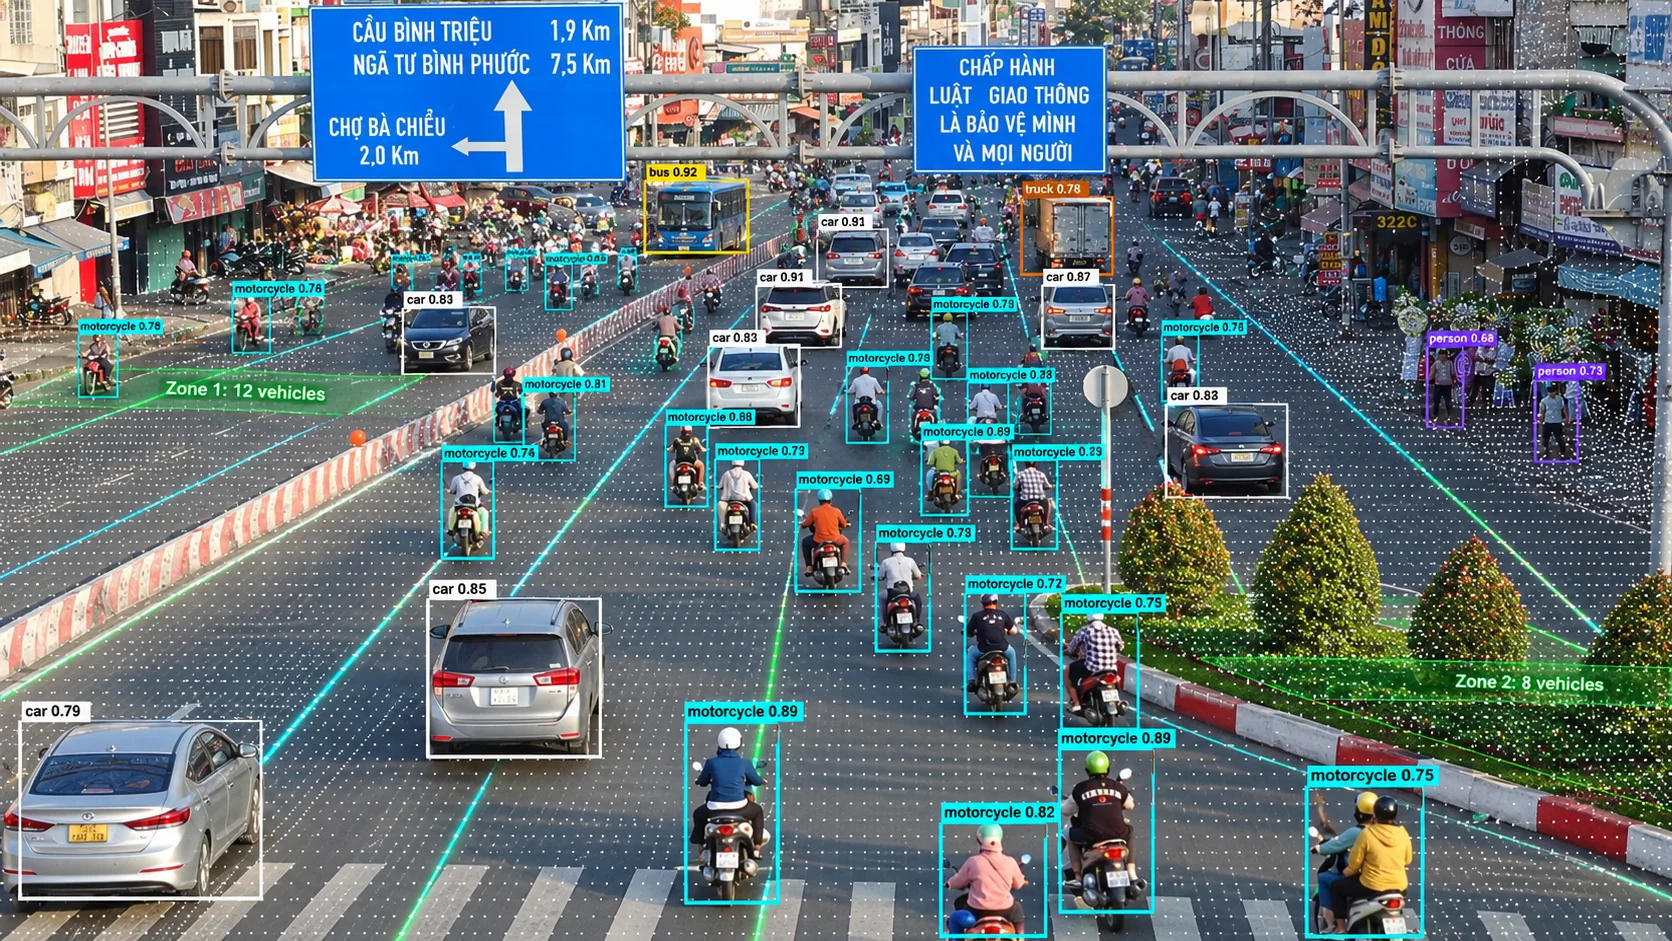
Add sensing and perception by site.
Process locally, operate centrally.
Manage many intersections and corridors.
Replay events and review decisions.
TeraFlow engineering principle
Monitor live traffic, inspect incidents and review site health across multiple locations.
Move between camera, 3D traffic context and recorded events without losing context.
Technology
Each stage has a clear input, output and operating role.
Synchronize camera, LiDAR and road context in time and space.
Turn sensor observations into spatial detections with confidence and source data.
Link detections into trajectories through movement, occlusion and sensor handoff.
Connect tracks, lanes, zones, events and infrastructure state in a live road model.
Run selected detection, tracking and privacy tasks close to the road.
Configure privacy zones, data retention and access for each deployment.
Inspect live and recorded traffic state, trajectories, events and system health.